Quantifying Error in Harmonic Reduction Systems
www.deerfieldfocalpoint.com/articles/quantifying-error-in-harmonic-reduction-systems

Abstract
Robotic arms require extreme precision to complete important and specific tasks. Yet, harmonic reducers, an extremely accurate type of gearbox that reduces backlash1, still struggle to achieve the necessary accuracy for complex tasks. Their sources of error fall into two major categories: static error, caused by imperfections in system construction and assembly, and dynamic error, caused by phenomena such as load's2 twisting effect on the flexspline3. Li et al. (2025) designed an experiment to quantify the error stemming from the straining of the flexspline under significant load. Their model predicted the machine error with 93-96% accuracy, and their results demonstrated that load had a greater effect on the accuracy of the harmonic reduction than manufacturing error did; sudden changes in load significantly affected the performance of the arm. Their results suggested a stiffer flexspline be used to reduce backlash and stabilize the load, and dynamic software adaptation to correct quantified load-induced error.
Introduction
Robotic arms require extreme precision to complete important and precise tasks. Small errors in angle compound as the target point moves further away from the axis of rotation. In robotic arms, which often stretch as long as four meters, small errors in angle can be significant. A typical error value in robotic arms using harmonic reductions of one arcminute (1/60th of a degree) can cause errors as large as 0.6 mm at the top of a two meter, a magnitude large enough to miss a target or drop a part during a space repair operation.
Most industrial and space arms use harmonic reductions because of their compact, lightweight design and their highly efficient reduction, enabling large torque ratios in one gear to gear interaction. The secret lies in a flexible rack [^1] which rotates by meshing its teeth with a rigid circular spline with more teeth. The flexible nature of this flexspline, however, is also the source of the harmonic reduction’s greatest inaccuracy: rotational inertia4 and sudden changes in torque warp the shape’s structural integrity.
Earlier studies attributed error in harmonic reductions to flaws in manufacturing and construction such as misshapen teeth and poorly coupled components. These errors cannot be addressed once the system is fully constructed. Li et al. (2025), however, hypothesized dynamic error to be more significant than static error, designing an experiment to prove their claim by quantifying both error types.
Fundamentals of harmonic reductions
Harmonic gearboxes are primarily made of three different parts: a wave generator, a flexspline, and a rigid outer/circular spline.
The wave generator is often the input for the system. Due to its oval shape which forces meshing of a number of teeth between the flexspline and the circular spline, the system is able to control precise and targeting movement while producing the large torque gear ratios that harmonic reductions are famous for (Harmonic Drive LLC, 2021).
The most defining characteristic of the harmonic reduction is the flexspline. As suggested in its name, the flexspline boasts impressive flexibility which it uses to hug the elliptical shape of the wave generator while also meshing with the circular spline. In order for it to function as intended, it often has two fewer teeth than the circular spline. The flexspline cannot be fixed upon the wave generator as it would lead to zero reduction in the system.
The circular spline serves as the stationary mechanism that the flexspline uses for movement. When the wave generator’s elliptical shape pushes two sections on opposing sides of the flexspline outwards, it pushes the offset teeth into each other, slightly shifting the flexspline to match the circular spline at those points.
The actual reduction produced comes from the offset and difference in teeth between the flexspline and the circular spline. In Li et al. (2025)’s experiment, the scientists used an outer ring with 242 teeth and a flexspline with 240 teeth, creating a shift of two teeth with every full rotation of the wave generator. Therefore, the gear ratio, which will be referred to as n, can be found by dividing the number of teeth of the circular spline by the difference in teeth between itself and the flexspline. This calculation produces a value of 121; the motor must turn 121 times to produce a full rotation in the flexspline.

Terms: ¹ Backlash: lost motion due to under-rotation. ² Load: external torque applied upon the output. ³ Flexspline: flexible gear that deforms to serve as the output. ⁴ Rotational inertia: resistance to rotational motion.
Methodology
Using the formula below, Li et al. (2025) focused on transmission error, which describes the position of the arm relative to where it should be under ideal circumstances:

- θ̃ — Transmission error
- θm — Input angle
- θl — Output angle
- n — Transmission ratio
- θk — With load step change
- θh — Without load step change
- θ̃p — Static error
- θ̃s — Dynamic error
Li et al. (2025) decided to analyze both static and dynamic error separately so as to isolate and measure the individual effects of each.
To model the error, the scientists ran experiments under a low rotational speed of 5 rpm with a 67 Nm load [^2]. The setup consisted of a fixed wave generator, held in place by code, which fought against any applied load. While the first motor held steady, a second motor gradually twisted output—the flexspline—from 0 Nm to 67 Nmto -67 Nm, and finally back to 0 Nm once more as the sensors tracked torque and rotation, allowing Li et al. (2025) to understand and model flexspline’s springiness.

Static error
Since static affects the system at the same spot of rotation with each axle turn, Li et al. (2025) were able to use a Fourier series expansion [^3] to model its effects:

To identify the order of the Fourier expansion, Li et al. used Root Mean Square Error (RMSE) [^4], plotting it against a Fourier expansion with a variable order [^3.5]. Their results showed that RMSE of the driving error dropped only nominally following the 240th order.

The scientists also tested the effects of static error upon a system with zero load. The model identified the lost motion caused from imperfect meshing and backlash caused by manufacturing error to be 1.341 arc min

Dynamic Error
To test for the dynamic error, Li et al. (2025) took the data from the setup of the fixed input motor and moving secondary motor, and they analyzed the data as a plot. The returned model showed a slightly non-linear curve, so the scientists fitted it along a fourth degree polynomial to model the non-linear nature of the flexspline’s elasticity:

Using the identified values of K, they found for Elastic Potential Energy formula of the flexspring using equations:
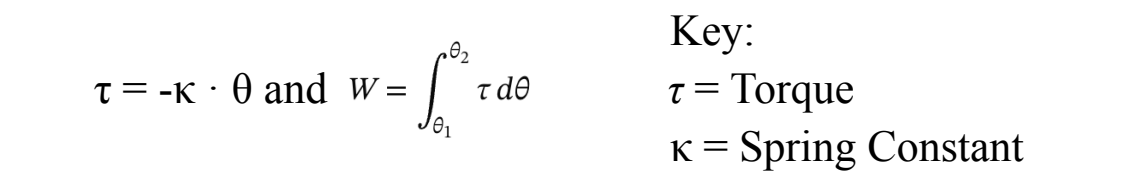
Combining these two formulas, Li et al. arrived to the following:

They then solved for the kinetic energy of the spinning ends of the system as well as total energy losses from dampening and friction, defining them respectively in the formulas below:

For dampening error and to consider power lost from friction, Li et al. (2025) used the following:

Finally, the scientists utilized the general Lagrange equation for the harmonic drive systems:

Li et al. (2025) synthesized the equations above and utilized Lagrange equations to predict the transmission error for any speed and load without needing to measure most of the specific qualities of each individual testing machine, eventually reaching a formula in:

To test how a sudden change in load affects the accuracy of harmonic reduction systems, Li et al. (2025) first started the system with a wave generator speed of 200 rpm with a 40 Nm load. After allowing the system to run for four minutes under these conditions, the researchers dropped the average load to 20 Nm and tracked the apparatus for another 5.2 minutes; they continued this process until they eventually increased the load to 60 Nm. From these changes in load, the scientists discovered that the change in magnitude of load was proportional to the actual change in driving error. A drop from 40 Nm to 20 Nm shifted the baseline position by -3.48 arcmin. Similarly, the error from the 40 Nm to 60 Nm shift creates a similar shift. Changes of load of similar magnitude, the team discovered, led to similar shifts in baseline position. Comparing the actual result to the model’s, Li et al. (2025) discovered the simulation result of 3.30 arcmin for a load change of magnitude 20 Nm to be only 0.18 arcmin away from the true result, an error of just 5.17%.
Conclusions
Li et al. (2025) were able to quantify the proportional error of static and dynamic sources using Fourier expansions and Lagrange modeling for each respective category. From their models, they found that dynamic error takes far greater precedence in considering shifts in baseline position than its static counterpart. External changes in load, the scientists determined, were the most limiting factors on a harmonic reducer’s accuracy.
To ameliorate the errors they discovered, Li et al. (2025) suggested using stiffer material for a flexspline to lessen the effects of dynamic error due to load changes. Furthermore, since their model was able to relatively accurately assess the error of the system, users of harmonic reducers could write software scripts to adjust according to predicted error.
[^#]: See supplementals on the following page.
Supplementals
[^1] Harmonic drive

[^2]
Li et al. used a load of ± 67 Nm because it was the maximum load the harmonic reducer used could withstand without overheating or damage to its elasticity.
[^3]
A Fourier series is a mathematical representation of the sum of repeating sine and cosine waves. Since position from rotational motion over time can be modeled as a wave-like function and all waves are summations of sine and cosine waves, a Fourier transformation is able to quantify a point’s motion. The fundamental formula for a trigonometric Fourier expansion is represented by:

The essential proof for the Fourier Expansion’s ability to model a complex wave lies in the fact that all waves are sums of other waves. When two waves collide, they either act in constructive or destructive manners, creating bumps, or reducing or increasing the amplitude of the crests and troughs. So, with enough waves added into the system, as described in the summation of the Fourier Expansion series, one can quantify any wave.
[^3.5]
The order of a Fourier series essentially dictates the number sine and cosine waves added to the overall sum. With a higher order, more sine and cosine waves are used to model the given shape, increasing the accuracy of the model.
[^4]
Funnily enough, the Root Mean Square Error is simply the root of the mean of the squared error. Root Mean Square Error, also called RMSE, represents the average residual error in a model. The closer the end results of the RMSE calculation, the more accurate it is, with zero representing a perfect fit. Though the RMSE method is very helpful in identifying fit when the actual model is similar to the actual value, it is very sensitive to large outliers as the residual error is squared in the calculation:

[^5]
The Lagrange equations used in this study serve to combine all known energy in the system (losses and gains) to predict error.4
Notes
- Harmonic Drive LLC. (2021). Harmonic drive® strain wave gear - zero backlash. https://staging.harmonicdrive.net/technology Back
- Li, R., Zhou, G., Zhao, Z., Li, J., & Wang, J. (2025). Analysis and prediction of transmission error of harmonic reducer for space robot. Space: Science & Technology, 5, Article 0233. https://doi.org/10.34133/space.0233. CC BY 4.0. https://creativecommons.org/licenses/by/4.0/ Back
- Britannica Editors. (2022, January 7). Harmonic Drive. Encyclopædia Britannica. https://www.britannica.com/technology/Harmonic-Drive Back
- Lecture L20 - Energy methods: Lagrange’s equations. (n.d.). MIT OpenCourseWare. Retrieved October 12, 2026, from https://ocw.mit.edu/courses/16-07-dynamics-fall-2009/b39e882f1524a0f6a98553ee33ea6f35_MIT16_07F09_Lec20.pdf Back


